I'm an incoming student in the Master of Science in Robotics program at
Carnegie Mellon University, where I plan to focus on robot learning, motion planning, and
end-to-end approaches — with an eye toward both the research and entrepreneurial sides of the field.
At IIT Bombay, my research centered on optimal control, adaptive model
predictive control, and system identification. In my first two years, I worked with Prof. Ravi Banavar
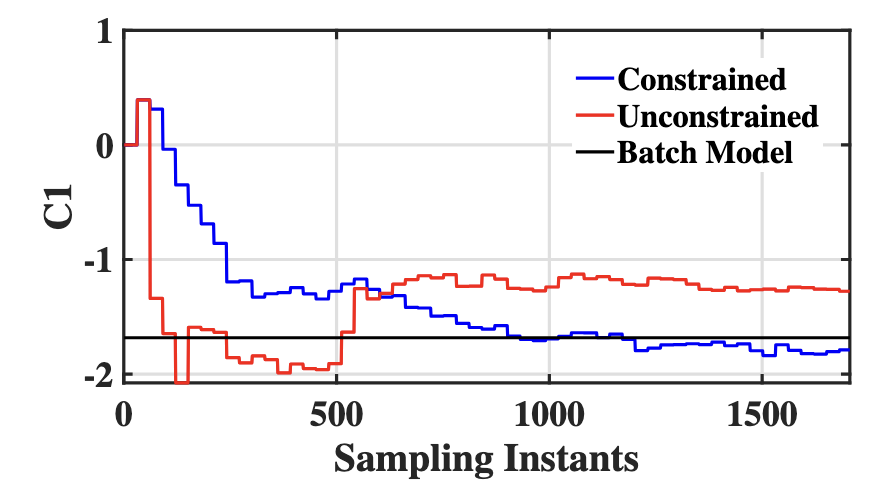
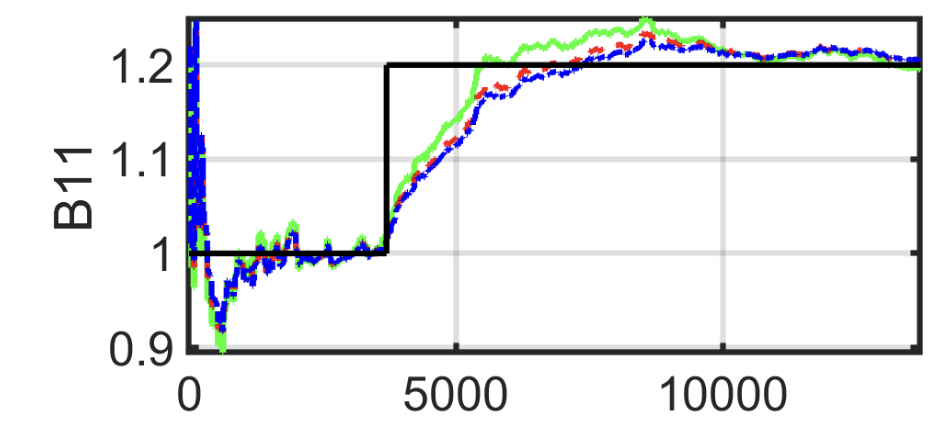
on building optimal control schemes for a plug-in hybrid electric vehicle. I went on to design novel data driven
system identification schemes for adaptive model predictive control under the guidance of Prof. Sachin Patwardhan
— work that received the R.G. Manudhane Award for outstanding M.Tech thesis.
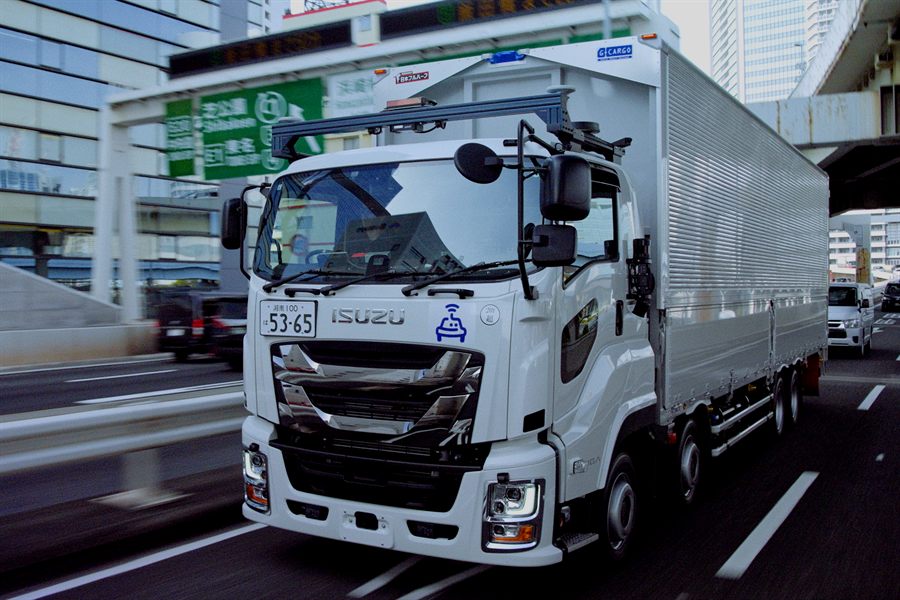
Most recently I was a Behaviour Planning Engineer on the trucking autonomy team at
Applied Intuition in Tokyo, where I worked on building motion planning
algorithms for autonomous trucking. I was previously an AI Researcher at
Honda R&D Tokyo, working on cooperative behaviour planning for
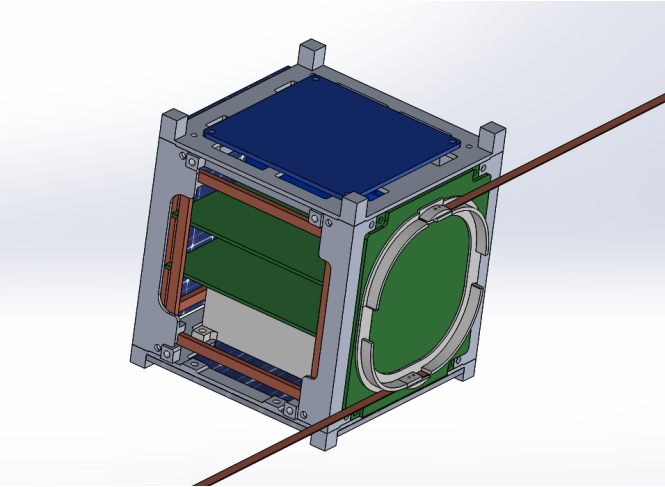
Honda's next-generation self-driving vehicles. I was also a part of the IIT Bombay Student Satellite Team,
where I worked on attitude control algorithms for a CubeSat sponsored by the Indian Space Research Organisation.