Publications

Papers and patents in control, estimation, and autonomy.

Papers

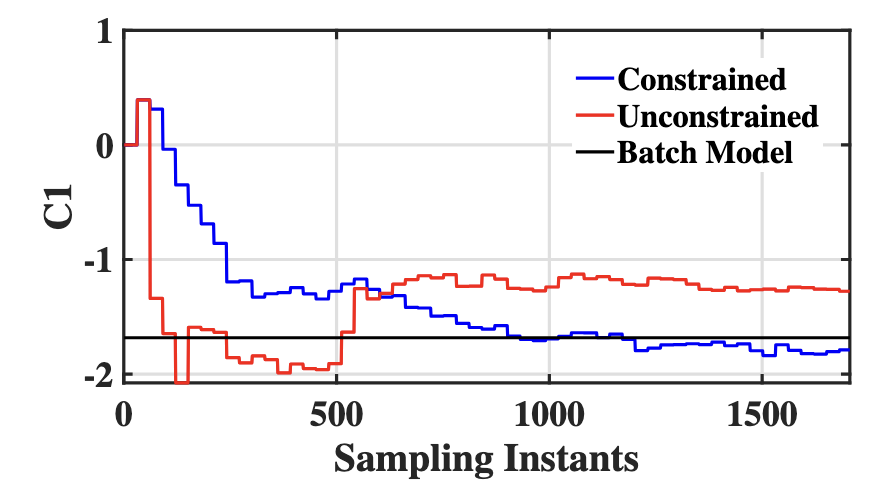
ARMAX estimation result plot from interview PDF
First author

Development of Block Iterated Extended Kalman Filter for Recursive Estimation of ARMAX Model Parameters

Indian Control Conference (ICC) ? 2023

Shrita Singh, Ashutosh Singh, Sachin Patwardhan

TL;DR: A shifting-window Block IEKF for online ARMAX parameter tracking, validated on simulation and quadruple-tank experiments.
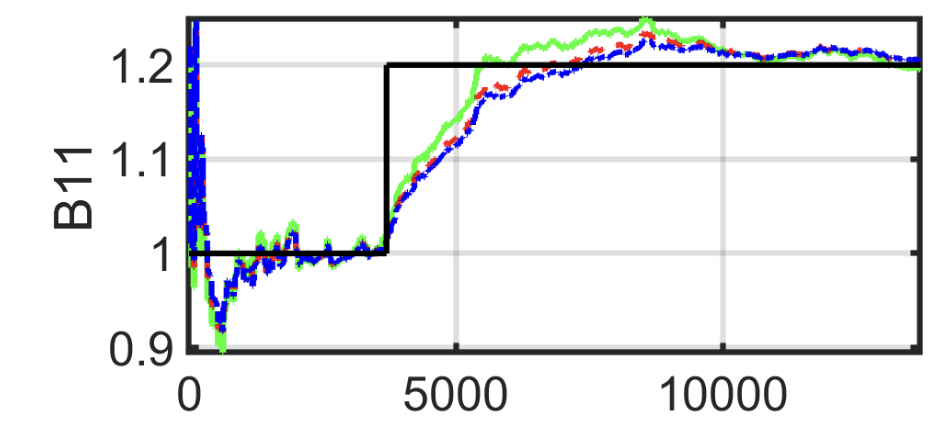
ARMAX model update result plot from interview PDF
First author

Development of Block Oriented Recursive and Constrained Parameter Estimation Schemes for ARMAX Models

IFAC Symposium on Dynamics and Control of Process Systems ? 2022

Shrita Singh, Kunal Kumar, Sachin Patwardhan

TL;DR: Block-data recursive updates with stability constraints for ARMAX noise models, tested on temperature control and quadruple-tank data.

Satellite trajectory figure from interview PDF
Co-author

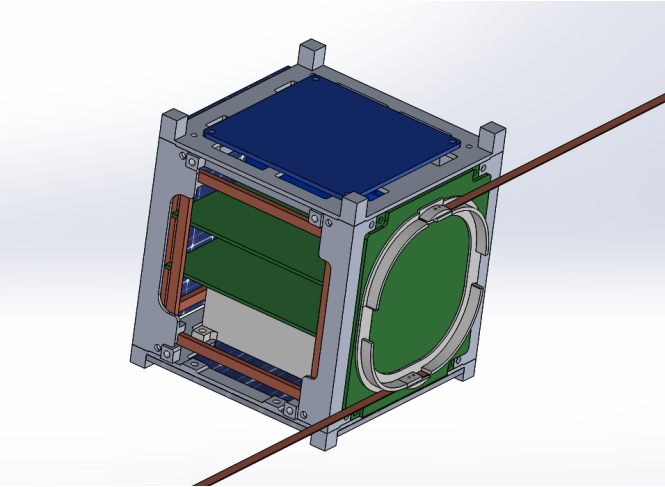
Closed Loop Simulation for Attitude Control of Nano-Satellite

Advances in Small Satellite Technologies, Springer ? 2020 / Int'l Conf. on Small Satellites and Systems ? 2019

Riya Singh, Shrita Singh, et al.

TL;DR: Modular closed-loop attitude dynamics simulation and on-board-in-loop PID validation for IIT Bombay?s student CubeSat.

Patents

Honda
Co-inventor

Path Refinement for Obstacle Avoidance

JP Patent H1240381JP01 ? 2024

Shumon Koga, Shrita Singh, et al.

TL;DR: Clothoid-based path refinement for lane changes and static obstacle avoidance in congested driving.

Honda
Co-inventor

Prediction for Obstacle Avoidance

JP Patent H1240478JP01 ? 2024

Rintaro Imamura, Shrita Singh, et al.

TL;DR: Cooperative behaviour prediction for safer, friendlier autonomous negotiation with other traffic agents.